AI research organization WiiLife has made significant strides in robotics with the introduction of its latest model, smolvla_candy_pick, published on November 5, 2026. This innovative model is designed to enhance robotic capabilities in tasks requiring vision and action integration, specifically in consumer-grade hardware environments. The model's architecture and performance metrics have been detailed in the global model registry, marking a pivotal moment for robotics applications.
Overview of smolvla_candy_pick
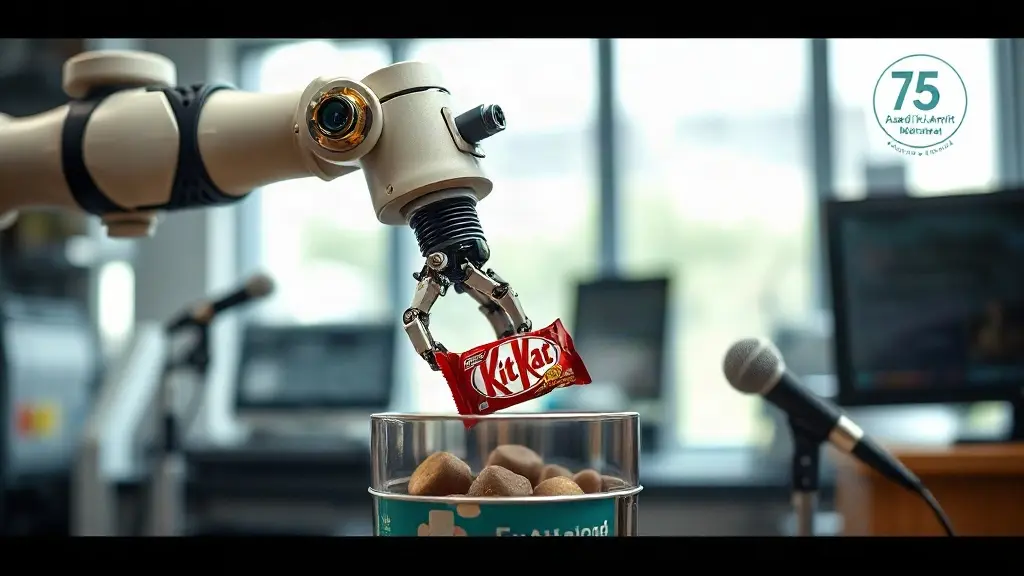
The smolvla_candy_pick model is a compact, efficient vision-language-action model that has been fine-tuned from the base model lerobot/smolvla_base. It is specifically trained to perform the task of picking up a KitKat mini and placing it in another bowl, showcasing its practical application in real-world scenarios. With a total of 50,000 training steps and a batch size of 64, the model utilizes the AdamW optimizer and a learning rate of 0.0001, ensuring optimal performance during its operational tasks.
Technical Architecture and Specifications
WiiLife's smolvla_candy_pick model is characterized by its unique technical architecture, which allows it to operate efficiently on consumer-grade hardware. The model boasts a memory throughput that is competitive with other advanced models in the field. The architecture includes several key features:
This table summarizes the input and output features of the model, highlighting its capability to process multiple visual inputs simultaneously. The model's design allows it to integrate observations from various cameras, enhancing its situational awareness and decision-making capabilities.
| Feature | Type | Shape |
|---|---|---|
| observation.state | STATE | (6,) |
| observation.images.camera1 | VISUAL | (3, 256, 256) |
| observation.images.camera2 | VISUAL | (3, 256, 256) |
| observation.images.camera3 | VISUAL | (3, 256, 256) |
| action | ACTION | (6,) |
Training Dataset and Methodology
The training dataset for smolvla_candy_pick is sourced from the BUasY3Phospo/kitkat_other_bowl repository, which includes 40 episodes and a total of 34,665 frames at a frame rate of 30 FPS. This extensive dataset provides the model with a diverse range of scenarios to learn from, ensuring robust performance in real-world applications. The training configuration was meticulously designed to optimize learning outcomes, with a seed value of 1000 to ensure reproducibility of results.
Practical Applications and Future Prospects
The introduction of smolvla_candy_pick opens up new avenues for robotics in various sectors, including manufacturing, logistics, and even domestic environments. Its ability to perform specific tasks with precision and efficiency makes it a valuable asset for companies looking to integrate robotic solutions into their operations. As the demand for automation continues to rise, models like smolvla_candy_pick will play a crucial role in shaping the future of robotics.
WiiLife's commitment to advancing AI technology in robotics is evident in the development of this model. The organization has provided comprehensive documentation and guides for users to train and deploy the model effectively, ensuring that even those new to robotics can leverage its capabilities.
Community Engagement and Open Source Contributions
WiiLife encourages community engagement by providing access to the model's architecture and training methodologies. Users can contribute to the model's development by sharing their experiences and improvements, fostering a collaborative environment that drives innovation in robotics. The model is licensed under Apache-2.0, allowing for modifications and adaptations by the community, which is essential for the ongoing evolution of AI technologies in robotics.
In conclusion, the launch of smolvla_candy_pick by WiiLife marks a significant advancement in the field of robotics. With its efficient architecture, robust training methodology, and practical applications, this model is set to redefine how robots interact with their environments. As the technology continues to evolve, the potential for smolvla_candy_pick and similar models to transform industries is immense.