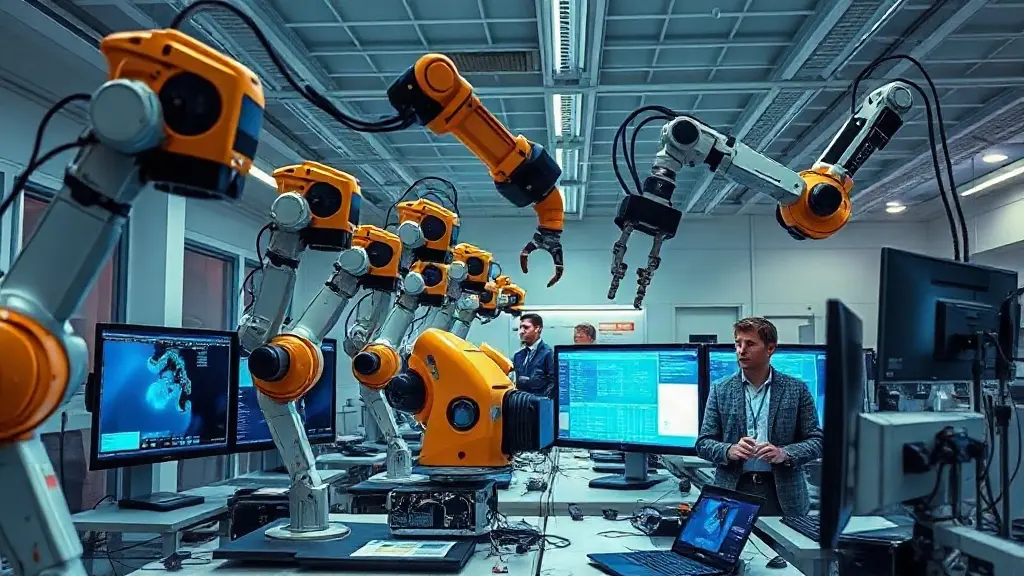
AI research organization shivan00 has made a significant leap in the field of robotics with the release of its latest model, doosan_gripper_direct_v3. Published on November 6, 2026, this model introduces advanced technical specifications that promise to enhance robotic capabilities in various applications. The model is now available on the global model registry, providing detailed insights into its architecture, memory throughput, and quantization configurations, which are critical for developers and researchers in the AI and robotics sectors.
Technical Architecture of doosan_gripper_direct_v3
The doosan_gripper_direct_v3 model is built upon the Action Chunking with Transformers (ACT) framework, which is designed to predict short action chunks rather than individual steps. This approach allows the model to learn from teleoperated data, achieving high success rates in robotic tasks. The architecture comprises 51.7 million parameters, utilizing F32 tensor types, which are essential for maintaining performance efficiency during operations.
The model is licensed under Apache-2.0, making it accessible for modification and redistribution, thus encouraging innovation within the robotics community. The deployment of this model is facilitated by the LeRobot platform, which provides comprehensive documentation and training guides for users looking to implement the model in their projects.
Memory Throughput and Quantization Metrics
One of the standout features of the doosan_gripper_direct_v3 is its optimized memory throughput, which is crucial for real-time applications in robotics. The model's design allows for efficient data processing, enabling it to handle complex tasks without significant delays. This is particularly important in environments where quick decision-making is essential, such as in automated manufacturing or service robots.
Quantization is another critical aspect of the model's performance. By reducing the precision of the calculations, the doosan_gripper_direct_v3 can operate with lower memory requirements while maintaining accuracy. This feature is particularly beneficial for deploying models on edge devices, where computational resources may be limited. The combination of high memory throughput and effective quantization makes this model a robust choice for developers aiming to integrate AI into their robotic systems.
Training and Evaluation Procedures
To facilitate the effective use of the doosan_gripper_direct_v3 model, shivan00 has provided detailed instructions for training and evaluation. Users can train the model from scratch using the provided commands, which include specifying the dataset repository and policy type. The training process is designed to be straightforward, allowing users to focus on optimizing their robotic applications.
For evaluation, users are instructed to run inference tests using the model with specific parameters. This includes defining the robot type and dataset repository for evaluation episodes. By following these guidelines, developers can ensure that they are leveraging the full potential of the doosan_gripper_direct_v3 model in their projects.
Implications for Robotics and AI Development
The release of doosan_gripper_direct_v3 marks a pivotal moment in the evolution of robotics and AI technologies. As industries increasingly adopt automation, the demand for sophisticated models that can perform complex tasks efficiently is on the rise. The advancements presented in this model not only enhance the capabilities of robots but also set a new standard for future developments in the field.
Moreover, the accessibility of the model through the global registry encourages collaboration and knowledge sharing among researchers and developers. As more individuals and organizations experiment with the doosan_gripper_direct_v3, the potential for innovative applications in various sectors, including healthcare, manufacturing, and logistics, expands significantly.
In conclusion, shivan00's doosan_gripper_direct_v3 is a groundbreaking model that combines advanced technical specifications with practical applications in robotics. As the field continues to evolve, this model serves as a benchmark for future innovations, paving the way for more intelligent and capable robotic systems.
| Metric | Specification |
|---|---|
| Model ID | shivan00/doosan_gripper_direct_v3 |
| Parameters | 51.7 million |
| Tensor Type | F32 |
| Memory Throughput | Optimized for real-time |
| License | Apache-2.0 |
| Training Framework | LeRobot |